Robotics
Robotic Packaging Cell
Vision-guided manipulation and mobile robotics
Safe Sentinel · 2025–2026 · 110 words · 1 min read
What
Project scope
Mechanical systems for automated packaging robots, including a mobile base, dual-arm layouts, and RealSense camera structures for object tracking.
How
Technical approach
Onshape · Robotics integration · RealSense · Rapid prototyping
Why
Outcome
Stable mechanics and repeatable tracking made the motion data more useful for training and improving robot performance.
Key evidence
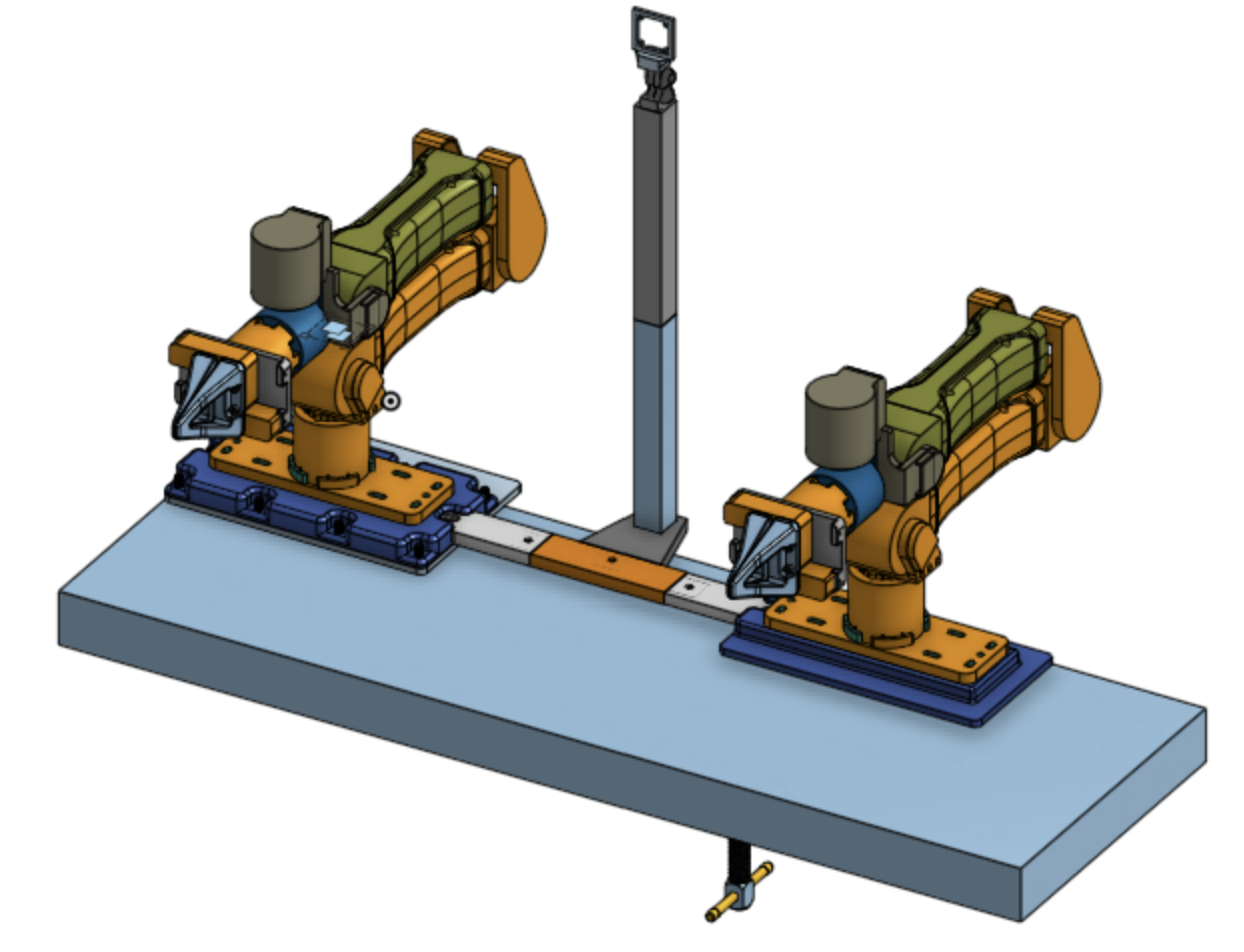
Process 01
Robot cell layout
I developed mechanical structures for automated packaging robots and a mobile base that let the vision and control stack operate in a repeatable physical environment. The work connected camera placement, robot reach, fixturing, and service access into one cell.
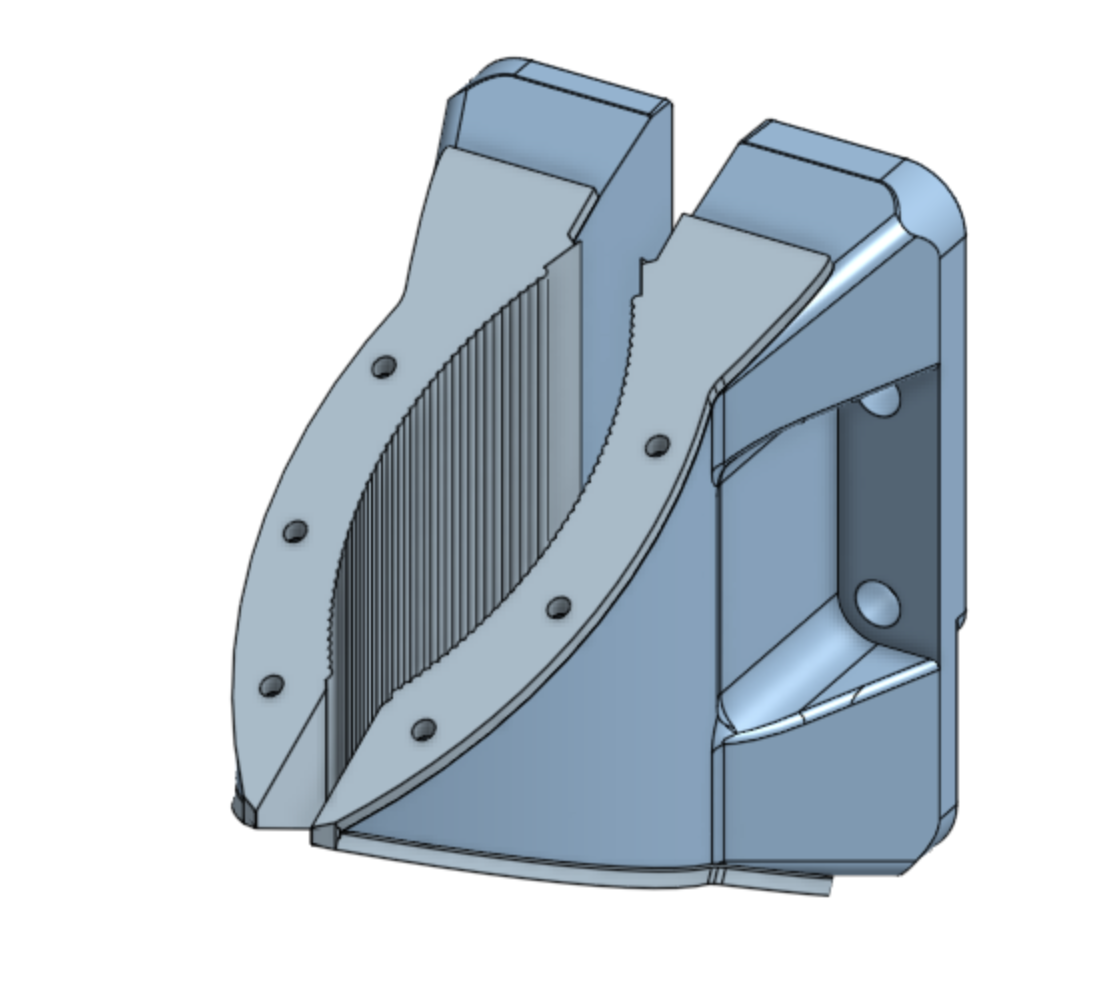
Mechanical layout and integration studies for the mobile platform.
Process 02
Camera placement and data collection
Human-teleoperated and VR-captured motion data were used to improve arm accuracy and repeatability. The mechanical design had to preserve clear sight lines, stable tracking geometry, and enough modularity to iterate as the training setup evolved.
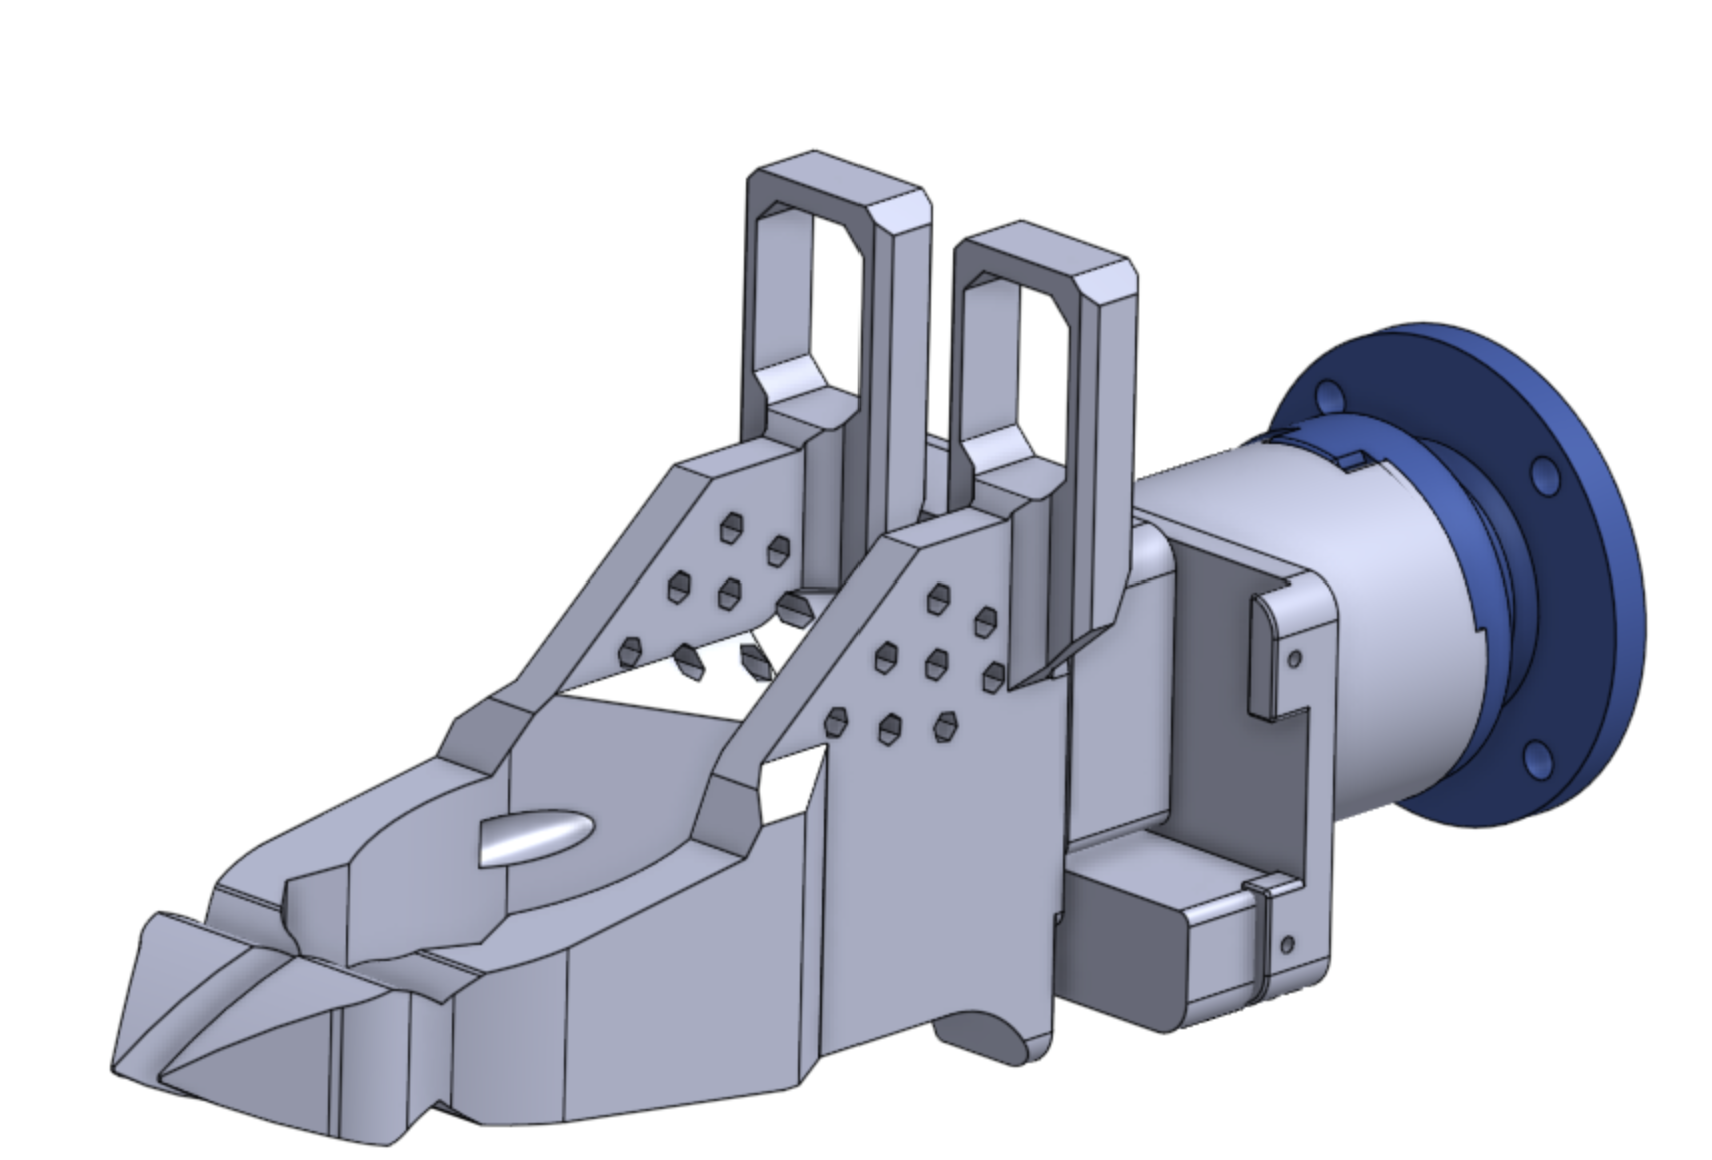
End-effector and workstation development details.
Project gallery