Camera Hardware
Apple Camera Hardware Engineering
Camera benchmarking, precision fixturing, and hardware validation
Apple · Summer 2026 · 162 words · 1 min read
What
Project scope
Camera benchmarking and hardware validation through Python SFR analysis, precision fixturing, and magnetic coexistence testing.
How
Technical approach
Python · SFR analysis · Siemens NX · PolyJet 3D printing · CNC machining · Hardware validation
Why
Outcome
The work created repeatable measurements and physical test evidence for comparing camera systems and validating module behavior.
Key evidence
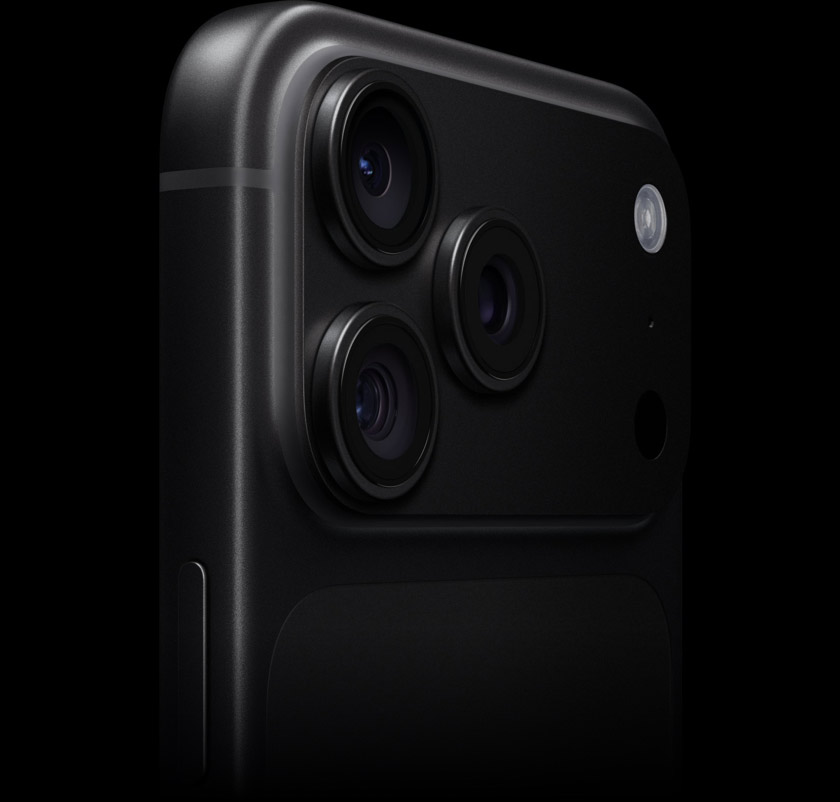
Process 01
Camera sharpness benchmarking
I developed a Python pipeline to benchmark iPhone camera modules against dSLR cameras using spatial frequency response (SFR), a quantitative measure of image sharpness. By evaluating performance across aperture conditions, the workflow enabled consistent cross-comparison between camera systems that did not share a native test environment.
Process 02
Fixture design and fabrication
To characterize coexistence interactions between camera modules, I designed a dedicated test fixture in Siemens NX and carried it through fabrication. I selected a combination of PolyJet 3D printing and CNC machining to produce the geometry and precision needed for repeatable hardware testing.
Process 03
Magnetic coexistence validation
I built test infrastructure for magnetic module coexistence and measured nodal force and sensor offset across operating conditions. The resulting data gave the team a physical basis for validating simulation results and understanding how module interactions changed throughout the operating envelope.
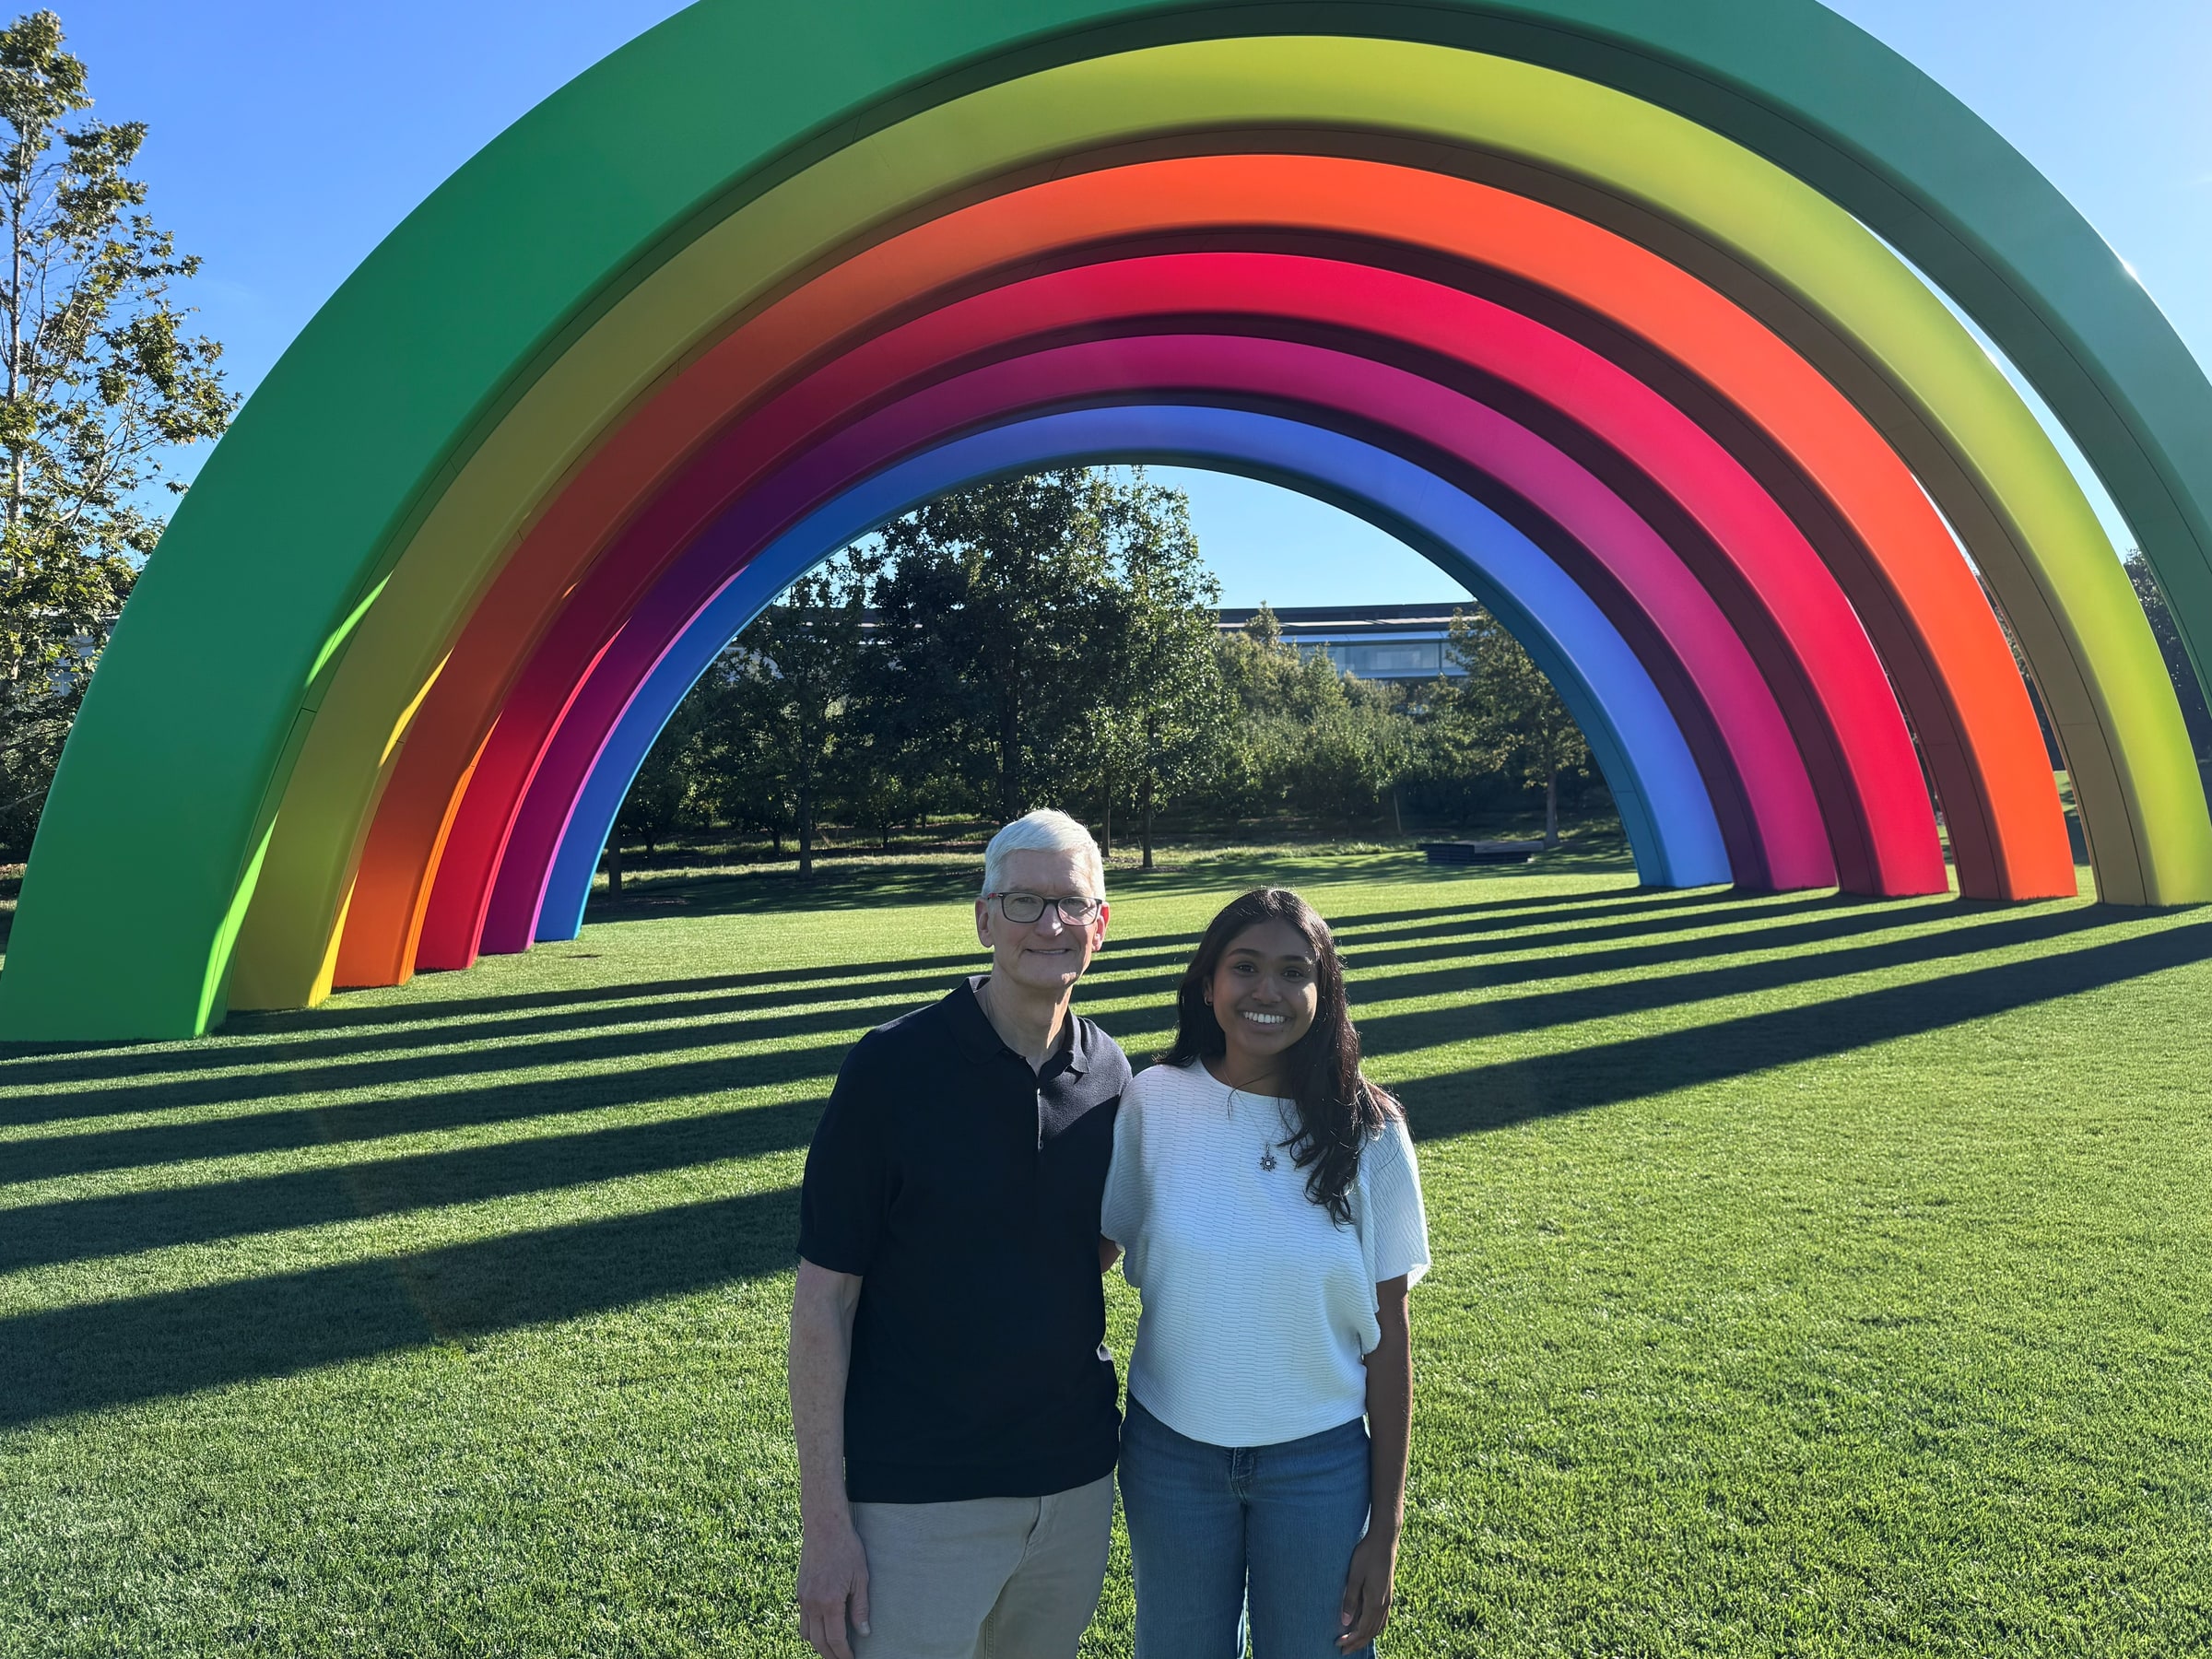
Was grateful to have met Tim Cook at Apple Park during my internship!