Competition Robotics
VEX Competition Robot
A field-ready mobile robot with a motor-sharing PTO
Perrybotics Team 742A · 2023–2024 · 113 words · 1 min read
What
Project scope
An 18-inch competition robot developed from strategy through CAD, custom fabrication, odometry, drivetrain tuning, and match testing for the VEX Over Under game.
How
Technical approach
Onshape · Autodesk Inventor · Machining · Laser cutting · Odometry
Why
Outcome
The robot translated match strategy into a durable mechanism that could be tuned, repaired, and driven under competition constraints.
Key evidence
Process 01
PTO drivetrain
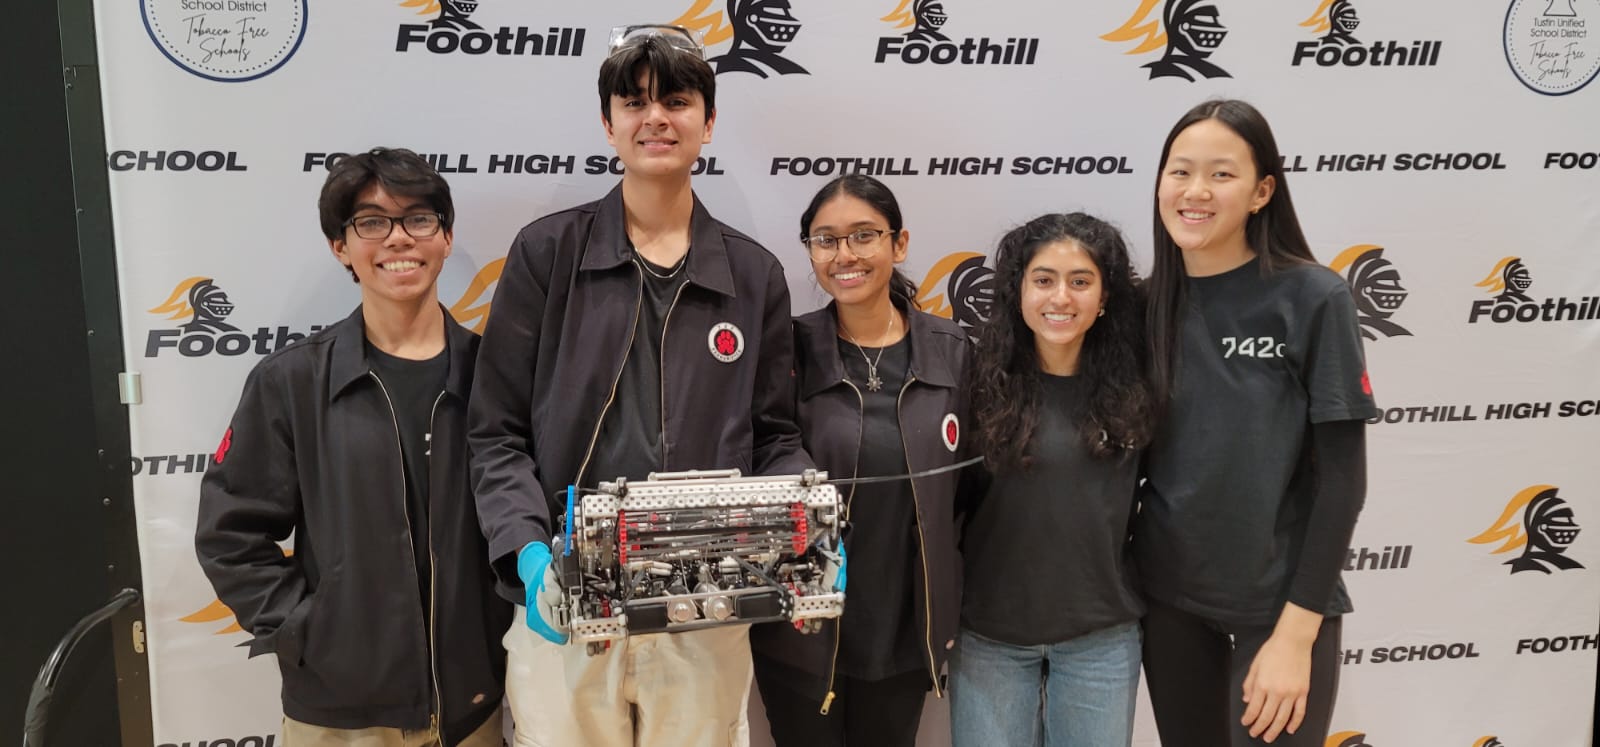
I designed a power take-off system that shifted two motors between the drivetrain and catapult. Piston-actuated locks changed functions during a match, while a compound gear ratio and ratchet system balanced range, precision, and durability.
The field-ready Over Under competition robot.
Process 02
Fabrication and testing
After CAD reviews I manufactured custom polycarbonate, aluminum, and geared components using laser cutting, mills, saws, and hand tools. Testing focused on straight-line drift, RPM and torque loss under load, intake compression, friction, and tolerance stack-up.